CNC Machine Tending Robots Manufacturer for CNC Loading and Unloading Automation
We manufacture CNC machine tending robots for automated loading and unloading of CNC lathes, machining centers, and compatible machine tools. Robot configurations are evaluated according to workpiece dimensions and weight, combined payload, working reach, gripping requirements, machine layout, and production targets.
We support automation integrators, machine tool distributors, industrial equipment manufacturers, and factories seeking to automate existing machining processes. Based on your application requirements, we can evaluate robot selection, gripper customization, and machine interface requirements to define a suitable configuration.
-
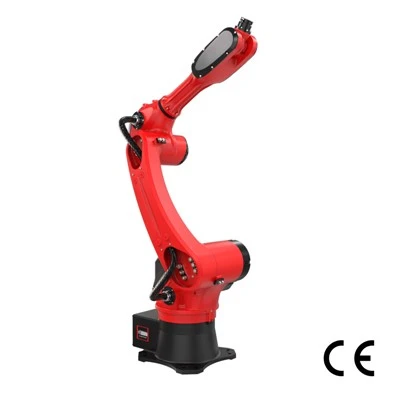
![CNC Loading Robot]() CNC Loading RobotThe RBTIC BRTIRUS0707A CNC Loading Robot automates workpiece loading, unloading and transfer for CNC machining operations.
-
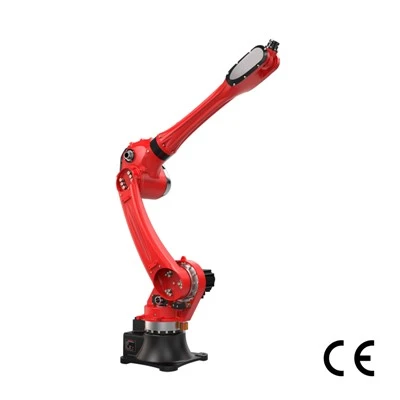
![CNC Robot Arm]() CNC Robot ArmThe RBTIC BRTIRUS1820A CNC Robot Arm is a 6-axis industrial robot designed for automated loading, unloading and workpiece transfer in machining and material-processing operations.
-
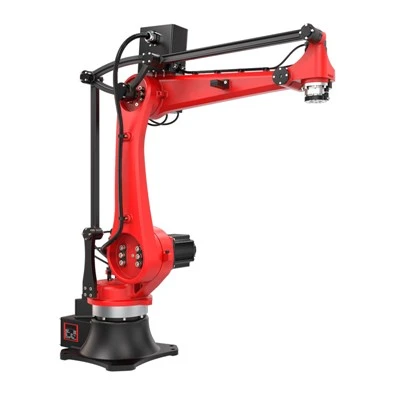
![CNC Machine Tending Robot]() CNC Machine Tending RobotThe RBTIC BRTIRUS2030A CNC Machine Tending Robot is a 6-axis industrial robot designed for automated workpiece loading, unloading and transfer in CNC machining operations. Its 30 kg rated payload...
-
![Machine Tending Robot]() Machine Tending RobotThe RBTIC BRTIRUS1510A Machine Tending Robot is a 6-axis industrial robot designed for automated workpiece loading, unloading and transfer in CNC machining operations.
-
![CNC Tending Robot]() CNC Tending RobotThe RBTIC BRTIRUS0805A CNC Tending Robot automates workpiece loading, unloading and transfer for CNC machining operations. Its 6-axis structure, 5 kg rated payload and 990 mm arm length support...
-
![Loading and Unloading Robot]() Loading and Unloading RobotThe RBTIC BRTIRUS2110A Loading and Unloading Robot is a 6-axis industrial robot designed for automated workpiece transfer between production equipment and handling stations.


CNC Machine Tending Robot Solutions
Automating CNC loading and unloading can help reduce repetitive operator tasks, improve workpiece handling consistency, and support more continuous machining operations. The actual benefits depend on the machine cycle, part handling requirements, operator workflow, and level of automation.
Our CNC machine tending solutions can be configured around your existing equipment and production needs.
Automated loading and unloading
Transfer raw workpieces into the machine and remove finished parts according to the agreed operating sequence.
01
Workpiece-specific handling
Configure grippers and gripping fingers to suit part geometry, weight, and contact surfaces.
02
Existing machine integration
Evaluate machine access, mounting space, control signals, and peripheral equipment before finalizing the configuration.
03
Production flexibility
Assess interchangeable tooling or alternative gripping setups when different workpieces need to be handled.
04
Application-based configuration
Match robot payload, reach, positioning requirements, and operating sequence to the actual machining task.
05
CNC Robot Product Series and Configurations
We evaluate CNC tending robot configurations according to the handling task, machine layout, workpiece requirements, and available installation space. The following table outlines the main configuration categories. Specific models and technical specifications should be confirmed against our current product range.
|
Robot Configuration |
Typical Application |
Key Selection Parameters |
|
Six-Axis Robot |
Flexible part handling, orientation, and transfer |
Payload, reach, repeatability, mounting position |
|
CNC Lathe Tending Configuration |
Loading raw parts into the chuck and unloading finished parts |
Chuck access, part geometry, gripping method, loading depth |
|
CNC Machining Center Tending Configuration |
Loading and unloading parts at designated fixtures or stations |
Fixture layout, workpiece dimensions, machine access, placement accuracy |
|
Customized Tending Configuration |
Application-specific handling and integration requirements |
Machine layout, tooling, control interfaces, production sequence |

Our CNC machine tending robots are intended for machining operations where workpieces must be repeatedly loaded, unloaded, or transferred between defined positions.
Typical Applications
- CNC Lathe Loading and Unloading: Pick up raw parts, load them into the chuck, and remove finished parts after machining.
- Machining Center Tending: Transfer workpieces to and from designated fixtures or loading stations.
- Batch Production: Automate repetitive handling tasks for production runs with defined workpiece and gripping requirements.
- Multiple Workpiece Handling: Evaluate interchangeable grippers or tooling arrangements for applications involving different part types.
- Machine-to-Machine Transfer: Assess part transfer between machines or stations when the layout, robot reach, and production sequence permit it.
CNC Compatibility Assessment
Before recommending a configuration, we review the following information:
|
Assessment Area |
What We Need to Check |
|
CNC Machine |
Machine brand, model, door arrangement, and available access |
|
Workpiece |
Dimensions, weight, geometry, and loading orientation |
|
Machine Interface |
Available signals, controller compatibility, and required operating sequence |
|
Installation Space |
Robot mounting position, reach, obstacles, and operator access |
|
Production Requirements |
Cycle time, part changeover frequency, and target output |
Workpiece and Gripper Customization
The gripper directly affects workpiece handling, positioning, and loading reliability. We evaluate tooling requirements against the part geometry and machine access conditions before confirming a suitable configuration.
|
Customization Area |
Available Options |
Evaluation Factors |
|
Gripper Type |
Pneumatic or electric grippers, where compatible |
Workpiece weight, gripping force, operating environment |
|
Gripping Fingers |
Custom finger profiles and contact surfaces |
Part geometry, gripping points, surface protection |
|
Workpiece Orientation |
Defined pickup and placement orientations |
Chuck or fixture access, part orientation, loading sequence |
|
Multiple Part Types |
Interchangeable tooling or application-specific gripping setups |
Part variations, changeover frequency, production requirements |
|
Gripper Integration |
Robot mounting, actuation, and agreed control signals |
Robot compatibility, tooling weight, available interfaces |
How Customization Works

Review workpiece information
Check drawings, dimensions, weight, material, and gripping points.
Evaluate the application
Assess machine access, loading positions, gripping requirements, and operating sequence.


Confirm the configuration
Agree on the gripper design, robot compatibility, interfaces, and customization scope.
Validate where required
Define whether a sample-part test, tooling trial, or integrated application test is needed before production or shipment.
Installation, Warranty, and After-Sales Support
For overseas buyers, the support arrangement should be clear before purchasing, particularly when the robot must be integrated into existing production equipment.
Depending on the agreed order and service scope, support arrangements may include:
|
Support Area |
Scope |
|
Technical Documentation |
Applicable operating and maintenance information |
|
Remote Technical Support |
Consultation and troubleshooting according to the agreed scope |
|
Installation Guidance |
Guidance for installation and setup where included |
|
Operator Training |
Training arrangements for designated customer personnel |
|
Spare Parts |
Part identification and supply arrangements |
|
On-Site Service |
Availability, location, schedule, and additional costs to be confirmed |
Warranty and Spare Parts
Warranty duration, coverage, exclusions, and claim procedures should be confirmed in the quotation or formal warranty documentation.
For spare-parts planning, buyers should confirm the identification method, ordering process, availability, and expected supply arrangements for relevant components.
Before placing an order, clarify whether installation, commissioning, training, and on-site support are included or quoted separately.
FAQ
As one of the most professional CNC robot manufacturers and suppliers in China, we have world-leading production equipment and strong manufacturing capabilities. Please feel free to buy durable CNC robot for sale here from our factory. Also, custom service is available.
Popular Products