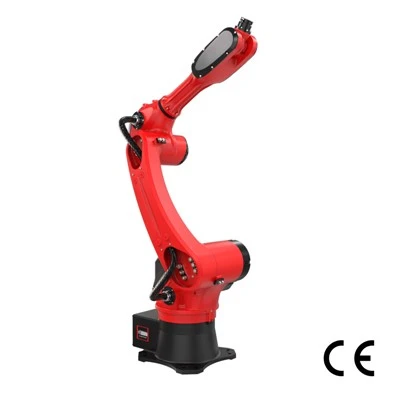
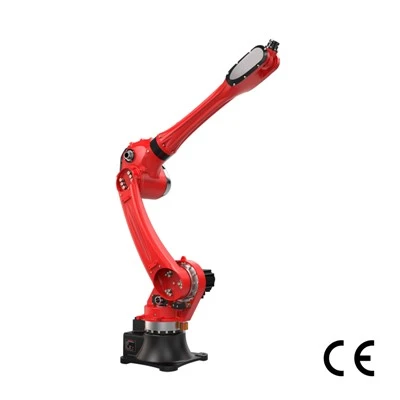
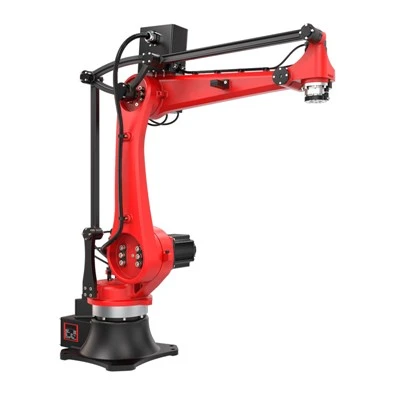
Industrial Robot Manufacturer for OEMs and Automation Integrators
We supply industrial robot solutions for machine tending, material handling, assembly, pick-and-place, and other automated production tasks. From robot selection and tooling requirements to technical documentation and application validation, we help OEMs and system integrators evaluate suitable configurations, reduce integration uncertainty, and prepare projects for procurement.
-
![6-axis Welding Robot]() 6-axis Welding RobotThe RBTIC BRTIRUS1510A is a six-axis industrial robot designed for automated welding of metal components and fabricated assemblies. With a 10 kg payload, 1,587 mm arm reach and ±0.05 mm...
-
![Welding Industrial Robot]() Welding Industrial RobotThe RBTIC BRTIRWD1506A is a six-axis industrial welding robot with a hollow wrist for internal cable routing and multi-angle torch positioning. It supports robotic welding applications using...
-
![Robotic Arm for Welding]() Robotic Arm for WeldingA six-axis industrial robot for welding and material handling – with flexible reach and repeatability, supporting programmed torch orientations for structural fabrication, aluminum guardrails,...
-
![Automatic Welding Robot]() Automatic Welding RobotA six-axis palletizing robot arm – paired with application-specific end-of-arm tooling – for flexible palletizing, depalletizing, loading/unloading, and material handling of cartons, bundled...
-
![Industrial Palletizing Robot]() Industrial Palletizing RobotA four-axis industrial robot, equipped with specialized fixtures, is suitable for lightweight pallet stacking, part handling, and the automated loading and unloading of metal components, battery...
-
![Palletizing Robot Arm]() Palletizing Robot ArmA six-axis 50 kg payload, 2563 mm reach palletizing robot arm – with application-specific end-of-arm tooling – for flexible palletizing, depalletizing, loading/unloading, and material handling of...
-
![Robotic Case Palletizer]() Robotic Case PalletizerDesigned for high-efficiency end-of-line packaging, the Robotic Case Palletizer integrates advanced industrial robotics with smart multi-pattern programming to handle cartons, crates, trays, and...
-
![Box Palletizing Robot]() Box Palletizing RobotA 65 kg payload, 2334 mm reach box palletizing robot – with column-based structure and 2400 mm vertical stroke – automating carton transfer and multi-layer stacking for heavy-load, high-level...
-
![Automatic Robotic Palletizer]() Automatic Robotic PalletizerAn 80 kg payload, 2412 mm reach automatic robotic palletizer – with programmable motion and application-specific tooling – for flexible stacking of large panels, cartons, and packaged products...
-
![Automated Palletizing Robot]() Automated Palletizing RobotA six-axis heavy-load industrial robot – with 200 kg payload and 2637 mm reach – delivering flexible, multi-orientation handling for heavy cartons, industrial containers, palletizing, and...
-
![Column Palletizer]() Column PalletizerThe Column Palletizer – with 65 kg payload, 2000 mm arm, and 1800 mm stacking height – automates carton and packaged-product transfer onto pallets, delivering repeatable stacking and efficient...
-
![Column Palletizing Robot]() Column Palletizing RobotThe RBTIC BRTIRPZ2080A Column Palletizing Robot automates the pickup, transfer and stacking of packaged products at the end of production lines. Its 80 kg payload and 2,000 mm arm length support...


Industrial Robot Types for Your Application
Choose a robot type based on your required motion, payload, working area, positioning performance, and production cycle.

6-Axis Industrial Robots
Flexible robotic arms for machine tending, part handling, welding, and multi-directional assembly. Suitable configurations depend on workpiece weight, tool load, reach, mounting position, and required tool orientation.
SCARA Robots
Designed for fast, repetitive operations within a defined working area, including component insertion, assembly, and pick-and-place. Selection depends on horizontal reach, vertical stroke, payload, positioning requirements, and cycle time.
Collaborative Robots
Suitable for selected assembly, machine tending, inspection, and flexible workstation applications. Model selection requires assessment of payload, reach, end tooling, workspace risks, and the intended human-robot interaction.
Delta Robots
Designed for high-speed picking, sorting, and packaging of compatible products within a defined working envelope. Configuration depends on product weight, gripper design, pickup pattern, cycle rate, and the required working area.
Cartesian Industrial Robots
Suitable for linear positioning, dispensing, machine loading, and controlled product transfer. Defined X, Y, and Z travel ranges can support applications requiring predictable motion paths and integration with production equipment.
Robot Model Range and Technical Specifications
|
Robot Type |
Reference Model |
Payload |
Reach / Working Range |
Repeatability |
Typical Application |
|
6-Axis Industrial Robot |
ER10-1400 |
10 kg |
1,400 mm reach |
±0.06 mm |
Machine tending, part handling, flexible automation |
|
6-Axis Industrial Robot |
ER20-1700 |
20 kg |
1,717 mm reach |
±0.06 mm |
Handling heavier components and larger work envelopes |
|
SCARA Robot |
OMRON Cobra 5 kg model |
5 kg |
500 mm reach |
±0.02 mm in XY |
Component assembly, insertion, and pick-and-place |
|
Collaborative Robot |
Delta DC10 |
10 kg |
1,200 mm reach |
±0.02 mm |
Assembly, machine loading, and flexible workstations |
|
Delta Robot |
Delta X S D800 |
2 kg |
800 mm working diameter; 300 mm working height |
±0.15 mm |
Lightweight picking, sorting, and product transfer |
|
Cartesian Robot |
Oriental Motor OVR 3-axis model |
2.5 kg |
X: 300 mm; Y: 300 mm; Z: 100 mm travel |
±0.02 mm |
Linear positioning, dispensing, and machine loading |
Configuration Options
|
Configuration Item |
Options or Requirements to Confirm |
|
Payload and reach |
Workpiece weight, tooling weight, required reach, and working envelope |
|
Mounting arrangement |
Floor, wall, ceiling, or machine-mounted installation where supported |
|
End-of-arm tooling |
Grippers, vacuum tools, welding torches, or other application-specific tools |
|
Controller |
Compatible controller model, operating requirements, and supported functions |
|
Electrical and communication interfaces |
Power requirements, I/O, supported industrial communication protocols, and PLC compatibility |
|
Positioning and motion |
Required repeatability, travel limits, speed, and cycle time |
|
Sensors and peripherals |
Vision systems, part detection, safety devices, and conveyor tracking where supported |
|
Environmental requirements |
Temperature, dust, moisture, cleanroom conditions, or other application constraints |
Engineering and Integration Support
1. Robot Selection and Application Review
Review workpiece specifications, payload including tooling, reach, mounting position, required motion, and target cycle time.
Project output: A shortlist of technically suitable models, identified constraints, and a list of information required to finalize selection.
2. End-of-Arm Tooling and Workcell Coordination
Assess the gripping or process method, tool interface, part presentation, fixture positions, and machine access requirements.
Project output: Agreed tooling requirements, interface details, and a clear list of included, optional, and customer-supplied components where applicable.
3.Controller and Equipment Integration
Review controller capabilities, available I/O, supported communication protocols, and connections to the customer's PLC and production equipment.
Project output: Applicable interface information, connection requirements, and a documented allocation of integration responsibilities.
Compatibility must be confirmed against the actual controller model, PLC, software version, and connected equipment.

Manufacturing Quality and Product Verification

Incoming Component and Assembly Checks
Where included in the manufacturing process, verify applicable component specifications, mechanical assemblies, mounting interfaces, and electrical connections against approved requirements.
Final Configuration and Shipment Inspection
Confirm the supplied robot model, controller, accessories, identification information, and order configuration against the approved order documents.
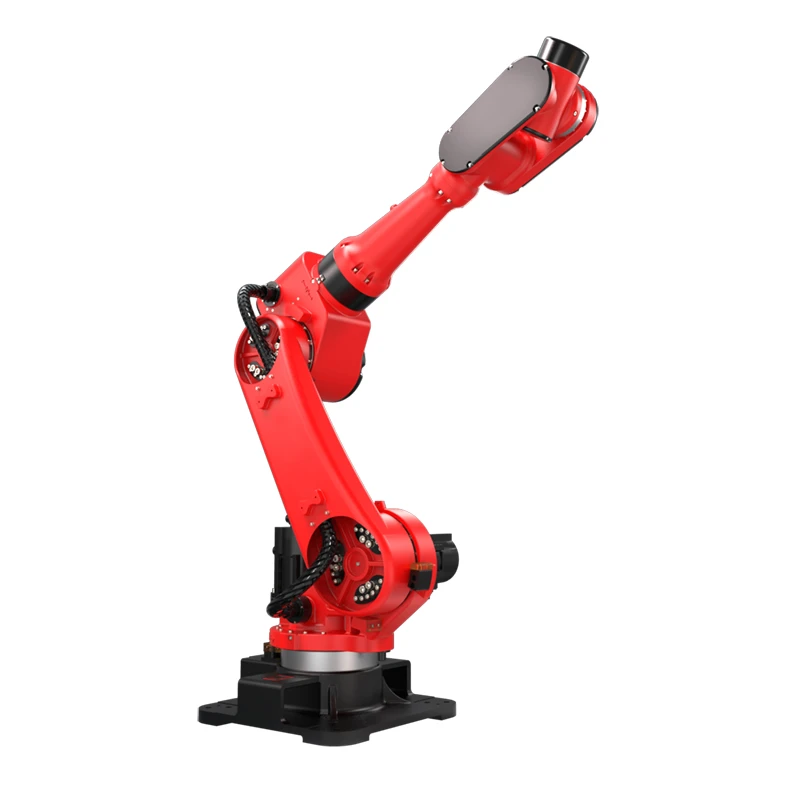
Functional and Motion Testing
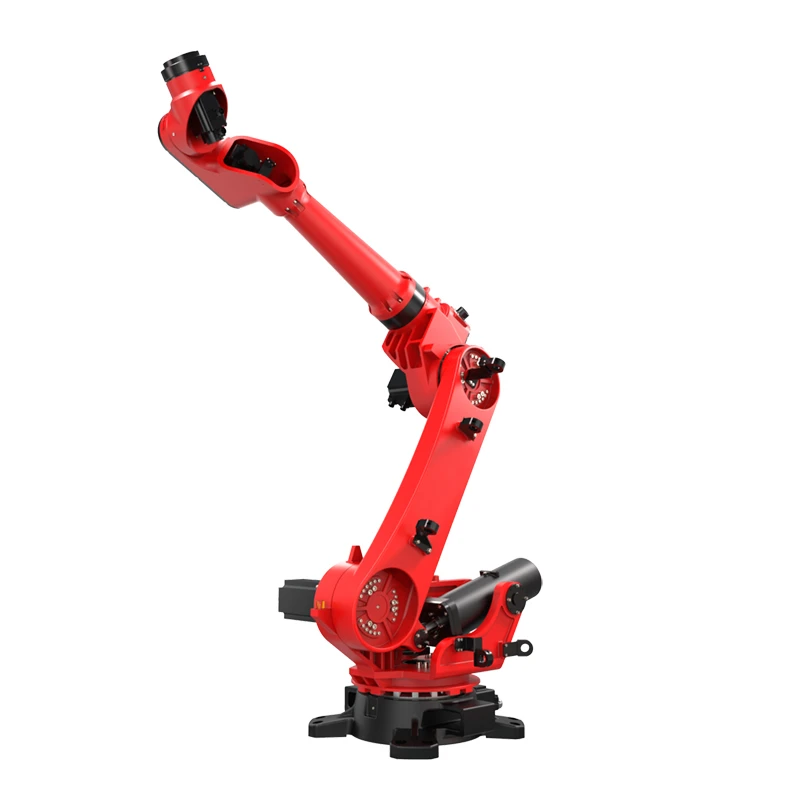
Operate the robot through agreed basic motion and functional checks. Additional tests may be required for application-specific sequences, positioning performance, or cycle time.
Mechanical And Electrical Inspection
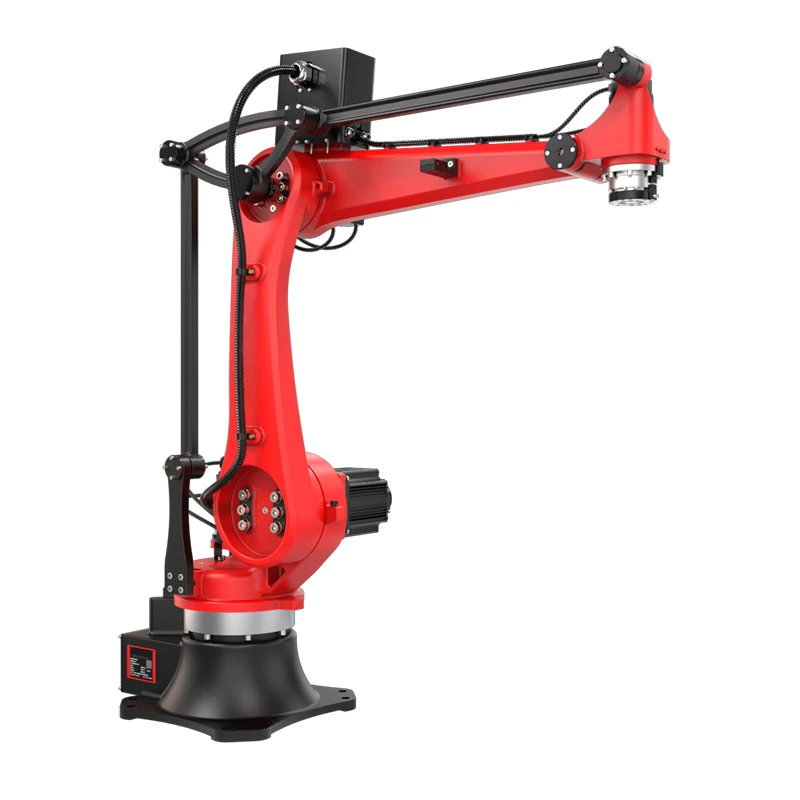
Check relevant mounting dimensions, mechanical connections, cable routing, electrical connections, and controller configuration before functional testing.
Quality Verification Records
|
Verification Item |
Purpose |
|
Model-specific datasheet |
Confirm rated specifications and operating conditions |
|
Mechanical drawings |
Check mounting interfaces and installation dimensions |
|
Configuration checklist |
Verify the ordered model, controller, and accessories |
|
Functional test records |
Document the agreed operational checks |
|
Performance test records |
Provide results for specific tests when performed and included |
|
Compliance documentation |
Confirm applicable product documentation for the destination market |
Technical Documentation and Deliverables

Before Purchase
- Model-specific datasheets and rated specifications.
- Available mechanical drawings and mounting dimensions.
- Controller, electrical, and communication interface information.
- Configuration recommendations based on the application requirements.
- Quotation identifying equipment, accessories, services, and delivery terms.
- Applicable product compliance information available for review.

During Project Preparation
- Confirmed robot model and configuration list.
- Applicable mounting, tooling, and interface details.
- Customer equipment and connection requirements.
- Integration responsibility matrix where required.
- Project drawings, I/O lists, or technical documents included in the agreed engineering scope.
- Agreed testing procedures and acceptance criteria where applicable.
Before Shipment and Delivery
- Supplied equipment and accessory list.
- Applicable inspection and functional test records.
- Available installation, operation, and maintenance manuals.
- Product identification and serial-number information where applicable.
- Applicable certificates or declarations for the supplied model.
- Commercial invoice, packing list, and other agreed shipping documents.
Ordering, Delivery and After-Sales Support
Quotation and delivery schedules depend on model availability, order quantity, configuration, engineering requirements, testing scope, and shipping arrangements.
A complete quotation should identify:
- Selected robot model and technical configuration.
- Included controller, tooling, accessories, and documentation.
- Optional equipment and separately charged services.
- Applicable engineering, testing, and preparation time.
- Estimated dispatch schedule and delivery terms.
- Payment terms, quotation validity, and warranty conditions.

Warranty and Technical Support
Warranty coverage depends on the supplied product and the agreed purchase terms. Before ordering, confirm the warranty period, covered components, exclusions, claim procedure, and responsibility for shipping or service costs.
Depending on the agreed service scope, support may include remote troubleshooting, operating guidance, technical documentation, or commissioning assistance.
For replacement parts or maintenance requests, provide the robot model, serial number where applicable, component identification, and a description of the issue.
Before placing an order for production-critical equipment, confirm:
- Which replacement parts are available.
- Part compatibility with the selected robot and controller.
- Spare-part pricing and estimated dispatch time.
- Recommended maintenance requirements.
- Availability of technical support and replacement components.

FAQ
As one of the most professional industrial robot manufacturers and suppliers in China, we have world-leading production equipment and strong manufacturing capabilities. Please feel free to buy durable industrial robot for sale here from our factory. Also, custom service is available.
Popular Products