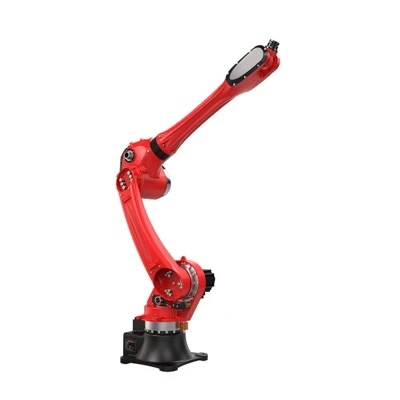
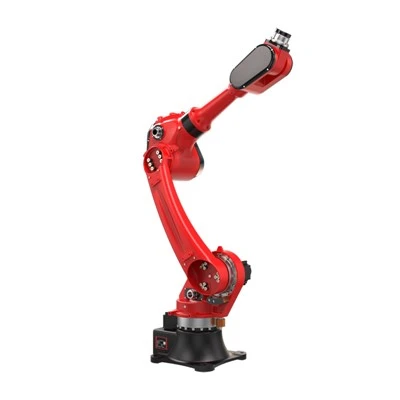
The RBTIC BRTIRUS1510A is a six-axis industrial robot with a 10 kg rated payload and 1,587 mm arm reach. Designed for automated pick-and-place operations, it provides ±0.05 mm repeatability for transferring components between defined pickup and placement positions.
Technical Specifications
|
Parameter |
BRTIRUS1510A |
|
Robot Type |
Six-Axis Industrial Robot |
|
Rated Payload |
10 kg |
|
Arm Reach |
1,587 mm |
|
Repeatability |
±0.05 mm |
|
J1 Range / Max. Speed |
±165° / 190°/s |
|
J2 Range / Max. Speed |
-95° to +70° / 173°/s |
|
J3 Range / Max. Speed |
-85° to +75° / 223°/s |
|
J4 Range / Max. Speed |
±180° / 254°/s |
|
J5 Range / Max. Speed |
±115° / 270°/s |
|
J6 Range / Max. Speed |
±360° / 342°/s |
|
Power Capacity |
5.06 kVA |
|
Power Supply |
220 V |
|
Robot Weight |
152 kg |
|
Control System |
HC Control System |

Product Features
Consistent Placement: ±0.05 mm repeatability supports repeatable positioning across production cycles, helping maintain placement consistency at defined target points.
Flexible Part Orientation: Six articulated axes allow the end effector to change position and orientation, supporting different approach angles without requiring the workpiece to remain in a fixed orientation.
Extended Reach: The 1,587 mm arm reach supports access to pickup and placement points across a larger work area, subject to the robot's working envelope.
Fast Wrist Rotation: J6 reaches a maximum speed of 342°/s, enabling rapid wrist rotation when the handling sequence requires changes in part orientation.
Workpiece Compatibility
Rated Payload up to 10 kg: Supports workpieces and end-of-arm tooling within the robot's rated payload limit.
Compact Components: Suitable for small and medium-sized parts, including metal inserts, plastic components, brackets and machined parts.
Rigid and Molded Parts: Supports components with defined gripping surfaces for pneumatic, mechanical or vacuum gripping, depending on part geometry and material.
Different Part Shapes: Application-specific grippers can accommodate varied component geometries, including flat, cylindrical and irregularly shaped parts, subject to tooling design.
Applications
Stamping Press Feeding: Pick stamped hardware parts, position them at the press and remove components in coordination with the machine cycle to reduce direct operator exposure to the stamping area.
Injection-Molding Insert Loading: Place metal inserts into mold cavities before mold closing, then remove finished parts after molding when the robot and molding machine are programmed to coordinate.
CNC Machine Tending: Load raw components into a machine and transfer finished parts to an output fixture or conveyor.
Assembly-Line Feeding: Move brackets, housings and other components from a feeding station to assembly fixtures for downstream processing.
Customization Options
Custom Gripper Design: Grippers can be tailored to workpiece dimensions, shape, weight and gripping surfaces to suit specific handling requirements.
Multi-Part Grippers: Customized tooling can handle multiple workpieces in one cycle when payload capacity and part spacing permit.
End-Effector Mounting: Tooling configurations can be adapted to the required pickup orientation and end-effector mounting arrangement.
Customized Handling Programs: Robot motion sequences can be programmed for specific pickup points, transfer paths and placement positions.

Machine and Line Integration
Machine Signal Coordination: Configured I/O signals can coordinate robot movements with machine-ready, cycle-complete and other defined operating signals.
Part Positioning: Trays, fixtures or feeding equipment provide repeatable pickup locations, supporting consistent handling sequences.
Production Sequence Control: Robot programs can coordinate pickup, transfer and placement with connected equipment. The required PLC interfaces, fault responses and safety interlocks depend on the integration scope.

Working Envelope and Installation
Reach Planning: The 1,587 mm arm reach must cover the actual pickup, placement and machine-access positions; the working envelope diagram should be used for layout planning.
Mounting and Clearance: Installation planning must account for the robot base, surrounding equipment, end-effector dimensions and the full movement path.
Cell Safety: Guarding, access interlocks and coordinated emergency-stop functions should be designed according to the integrated cell's risk assessment.
FAQ
Q: What programming methods does the BRTIRUS1510A support?
A: Programming and teaching methods depend on the supplied HC Control System configuration. Confirm supported teaching functions, program storage and editing capabilities before ordering.
Q: Can the BRTIRUS1510A run continuously across multiple shifts?
A: Multi-shift operation depends on cycle frequency, duty requirements, maintenance intervals and the reliability of the complete automation cell. Confirm the intended operating schedule and service requirements during project evaluation.
Q: What acceptance tests should buyers request before shipment?
A: Buyers can request a factory acceptance test covering specified robot movements, repeatability checks, controller functions and agreed operating sequences. Test criteria and documentation should be defined in the purchase agreement.
Q: What maintenance is required for the BRTIRUS1510A industrial robot?
A: Routine maintenance generally includes checking cables, connectors, mounting fasteners and manufacturer-specified lubrication points. Request the official maintenance schedule and recommended spare parts list for the supplied configuration.
Q: What is included when purchasing the BRTIRUS1510A robot?
A: The supply scope may differ by quotation. Confirm whether the price includes the robot arm, controller, teaching pendant, cables, software and documentation, and whether commissioning or operator training is included.
Q: What is the lead time for the BRTIRUS1510A robot?
A: Lead time depends on stock availability, order quantity and the agreed supply scope. Request a confirmed delivery schedule that distinguishes standard robot supply from any additional engineering or commissioning work.
Hot Tags: industrial pick and place robot, China industrial pick and place robot manufacturers, suppliers, factory